Vigilant Robot Swarms for Environmental Monitoring
As decentralised robot teams, or ‘swarms’, move from the laboratory into the real world there is a clear opportunity to enhance the monitoring of different environments, for purposes ranging from scientific surveys to security. Our work focuses on how diverse types of robots, in form and behaviour, can contribute to enhanced collective awareness of a location. We consider smaller, more ‘sparse’ swarms of fewer robots (<10) as this is more realistic for real-world deployment.
- What the swarm senses
Several of our projects relate to sensing the electromagnetic environment (EME); we’ve also considered atmospheric electrostatics, including Mars, and radiation monitoring in the context of nuclear decommissioning. Often this is with a view to anomaly detection in longer-term patrolling.
- Diversity and adaptability in collective behaviour
Drawing on collective animal behaviour, we’ve examined the concept of ‘functional heterogeneity’ (i.e., inter-robot differences that deliver a functional benefit) in field trials. We consider how diversity in behavioural traits and roles helps with managing trade-offs in coverage vs anomaly investigation, or supports collective decision-making.
- Robots working with and around people
Following a major EPSRC-funded project in trust in human-robot teams, we’ve developed expertise in human-robot interaction (HRI). In addition to trust experiments, we consider human and robot navigation among crowds and evacuation.
- Real-world environments
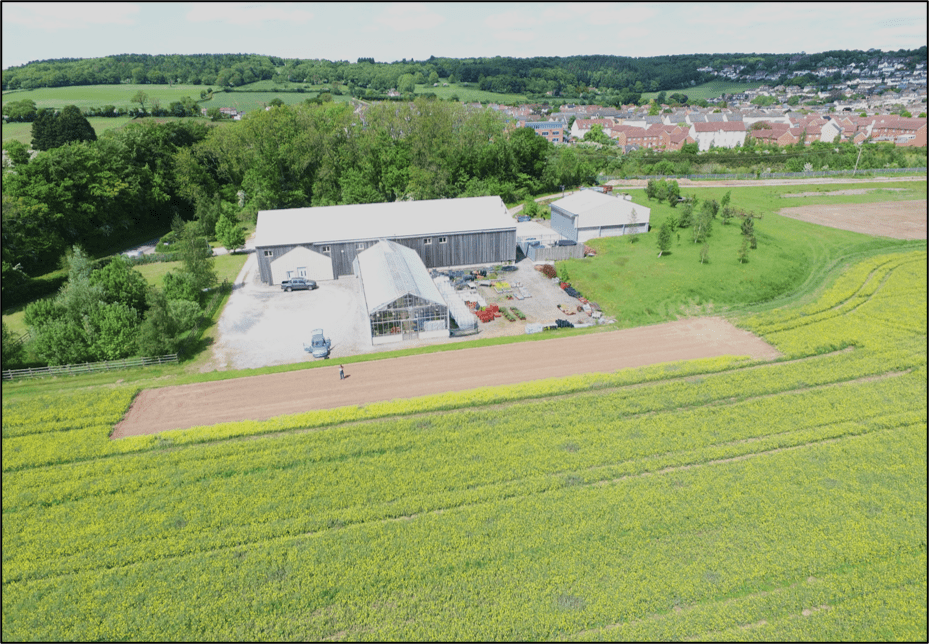
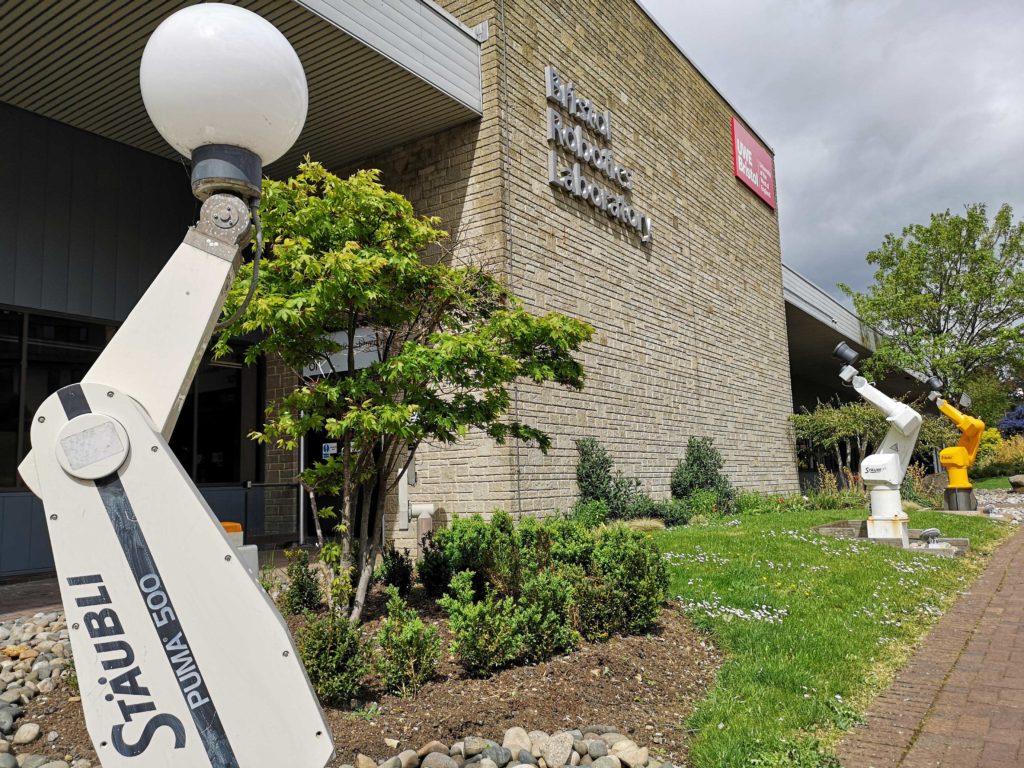
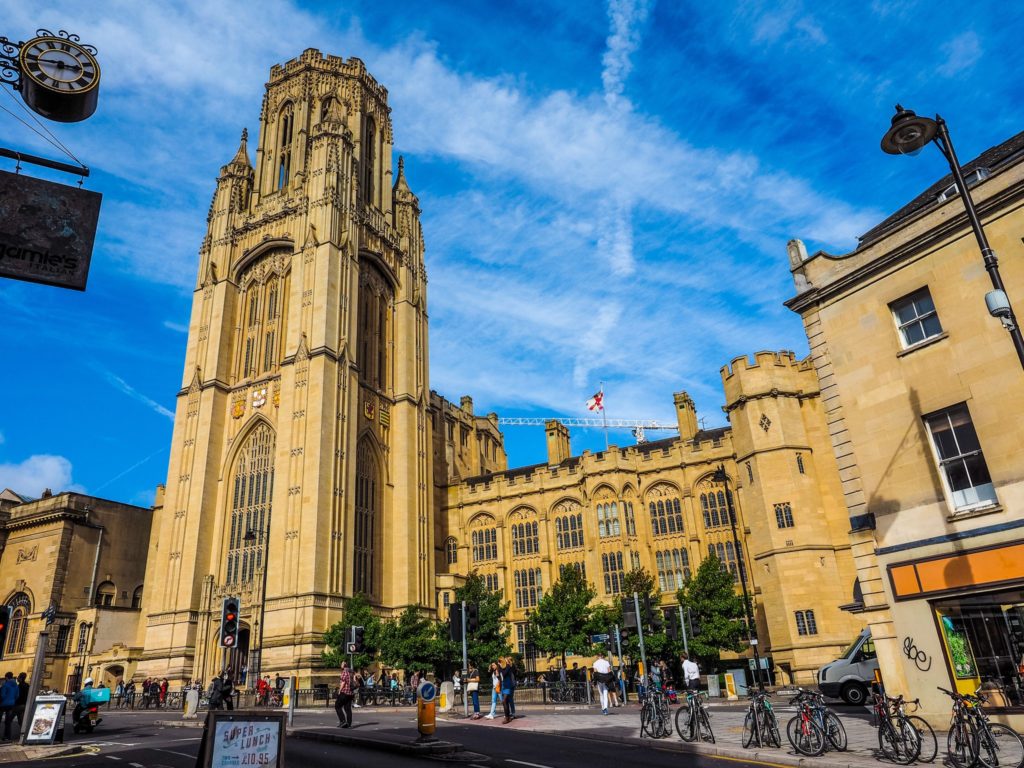
Our field trials are carried out in a range of indoors and outdoors locations: in university office buildings, and at Bristol’s Fenswood Farm facility in Long Ashton, Somerset (below left). We also have access to the Bristol Robotics Laboratory (below centre), which is on the UWE campus in north Bristol. Our day-to-day desk work is carried out on the Clifton campus (below right) in the centre of Bristol.
Below we show a few specific examples from our ongoing research themes – please see the publications page and Edmund’s university page for the full breadth of our activity.
Robots
Our group primarily works with rovers (ground-based robots), and we have obtained several ‘Leo Rovers’ for our experiments. Previously we have also worked with ‘Kilobots’ for conceptual swarm research. As our research develops, we will examine heterogeneous swarms (i.e. different robot types) including e.g. quadruped (4-legged) robots and drones in our swarm deployments.
Collective Perception in Patrolling Swarms
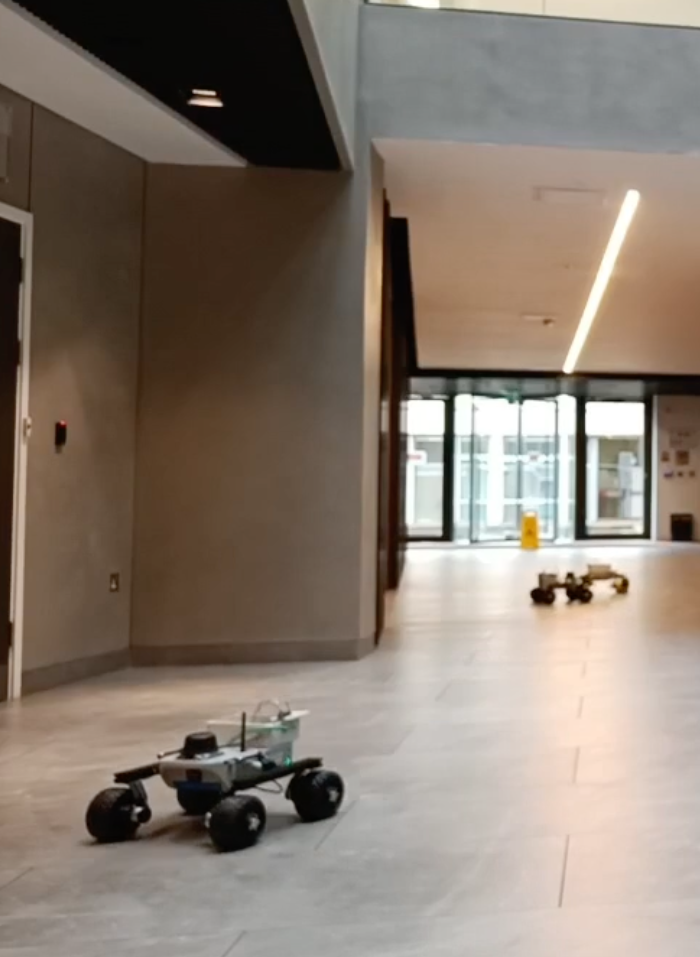
Making decisions collectively is an important capability for many animal groups, such as ant or honeybee colonies. Bioinspired collective decision-making algorithms have been studied in simulated and real robot swarms.
We are investigating how swarms of patrolling robots can better understand their shared environment, through different information fusion rules, in the context of the distributed patrolling problem and deciding where anomalies have been found.
Lead Researcher: Zachary Madin
Co-Supervisor:
Prof Jonathan Lawry
Funding
UoB Scholarship
Investigating Functional Heterogeneity
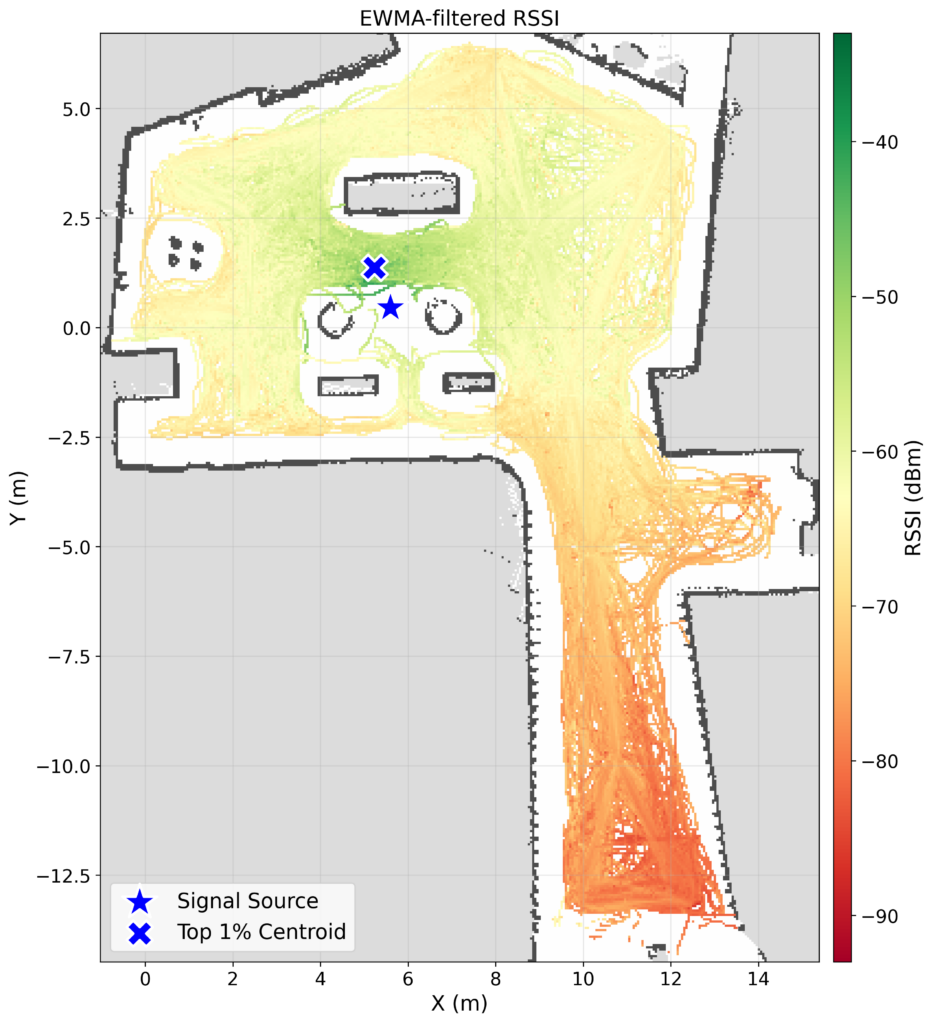
Functional heterogeneity – i.e. differences within groups that have an adaptive, functional purpose – is increasingly recognised as important in animal groups. We want to demonstrate this principle in robot swarms.
Patrolling robots can sense their electromagnetic environment (EME), i.e. the radio activity going on in a space from things like Wi-Fi networks, to better secure it. Different behavioural roles or traits could help them to do this more effectively.
Lead Researcher: Connor York
Co-Supervisor:
Dr Paul O’Dowd
Funding
FCDO Services
Multi-Agent Task Allocation and Pathfinding
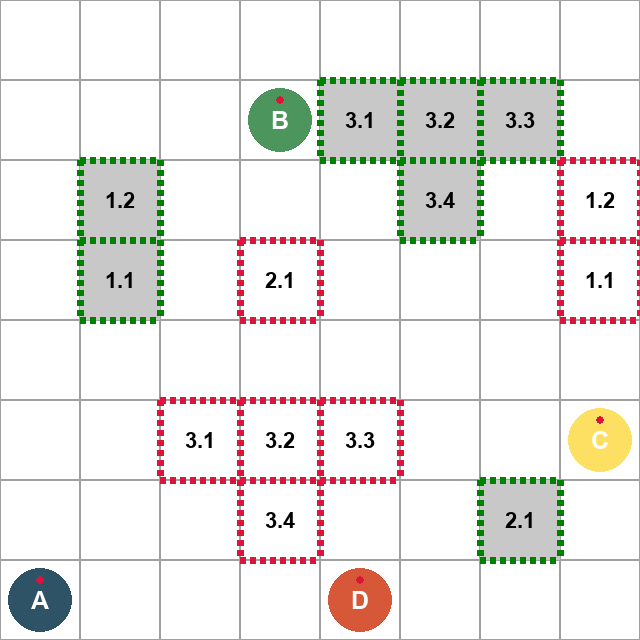
Multi-robot systems are integral to modern logistics, and are used in contexts such as warehouses to carry items for storage and dispatch. Research so far has mostly focused on deconfliction between the paths of individual agents, rather than active cooperation. We consider the Cooperative Transportation Task Allocation and Path Finding (CT-TAPF) problem, where robots have to work together to carry loads.
Ning also considers human-robot interaction with MRS in his ongoing research.
Lead Researcher: Ning Zhou
Co-Supervisor:
Dr Nikolai Bode
Funding
China Scholarship Council
Robotics for Environmental Science
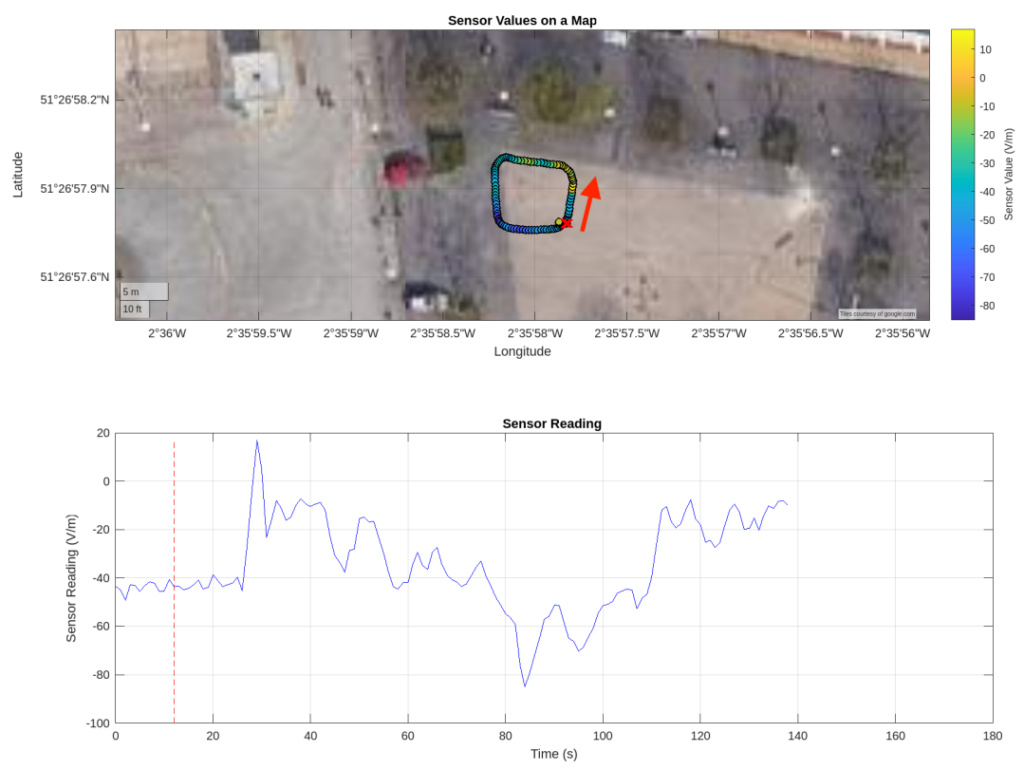
Atmospheric electricity is not very well understood – least of all on other planets such as Mars. There are ongoing scientific efforts to understand the influence of electrostatics on weather, as well as their impact on future habitation on Mars.
We have explored new frontiers in electrostatic measurement by putting sensors on mobile outdoors robots, who can plan their collective movement to obtain new insight into electrostatic phenomena.
Lead Researcher: Gjosse Zijlstra
Co-Supervisor:
Prof Karen Aplin
Funding
FARSCOPE CDT
Effective Patrolling Behaviours
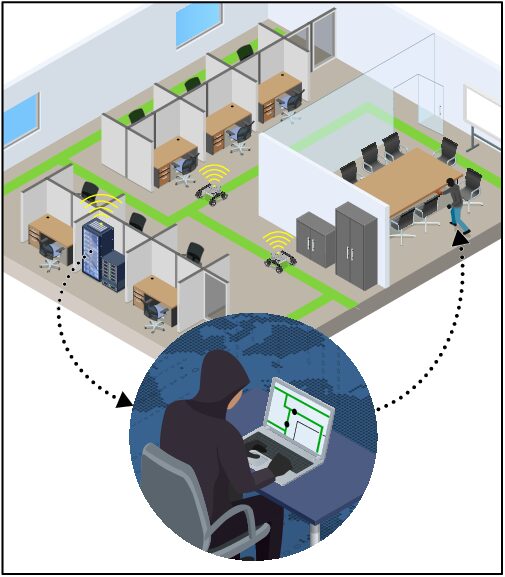
We want to deploy teams of robots into real-world environments to monitor activity to ensure anything anomalous can be detected and investigated. In a multi-robot / swarm context, there is a clear opportunity to exploit cooperation between robots to verify anomalous findings by sending follow-up patrols.
There is a class of ‘adversarial patrolling’ algorithms that have already been developed, but not benchmarked robustly so far. We develop new adversary models to ‘red team’ patrol algorithm performance.
Lead Researcher: James Ward
Co-Supervisor:
Prof Arthur Richards
Funding
FARSCOPE CDT
Trust in Human-Robot Teams
I am Co-Investigator on the £1.2M EPSRC-funded project ‘Satisficing Trust in Human-Robot Teams’, running 2023-26.
Dr Nicola Webb (Research Associate) has joined the Hunt Lab at Bristol to carry out human-robot teaming experiments where we study factors affecting trust, and how that trust can be managed and suitably enhanced.
There’s more information at a blog hosted by the Bristol Digital Futures Institute.

Lead Researcher:
Dr Nicola Webb
Project PI:
Prof Chris Baber (Birmingham)
Funding
EPSRC